

All Products
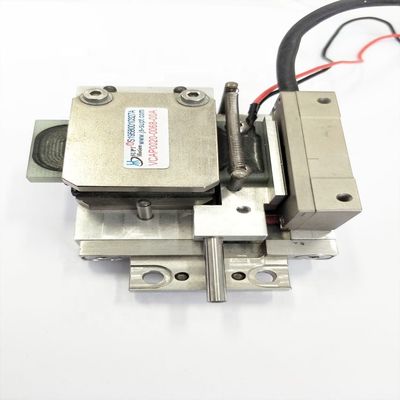
Parallel Jaw Micro Gripper with 20N Linear Voice Coil Motor for Robotic Wafer Handling


| Place of Origin | Suzhou, Jiangsu, China |
|---|---|
| Brand Name | SUPT MOTION |
| Certification | ISO 9001:2015, CE |
| Model Number | VCAP-G Custom Gripper |
| Minimum Order Quantity | 1 Set |
| Price | USD 120-400 / Piece |
| Packaging Details | Cleanroom bag, ESD safe tray, shock absorbing foam, export carton with desiccant |
| Delivery Time | 5-7 working days for samples, 18-25 working days for batch orders |
| Payment Terms | T/T |
| Supply Ability | 120 Sets per Month |
Product Details
| Model | VCAP0020-0068-00A | Actuator Type | Flat Planar Voice Coil Actuator, Moving Coil |
|---|---|---|---|
| Peak Force | 20 N (intermittent) | Continuous Force | At 25°C 5.5 N |
| Total Stroke | 6.8 Mm | Maximum Voltage | 8.2 V |
| Back EMF Constant | 4.4 V/m/s | Length × Width × Height | 39 × 50 × 21.5 Mm |
| Environment | ISO Class 5, Vacuum Option | Customization | Jaw Geometry, Stroke, Force, Mounting |
| Typical Application | Robot Die And Wafer Handling | ||
| Highlight | Robot Micro Gripper Voice Coil Module,Programmable Grip Force 20N Jaw Actuator,Compact Structure Parallel Jaw Module |
||
Product Description
Product Overview
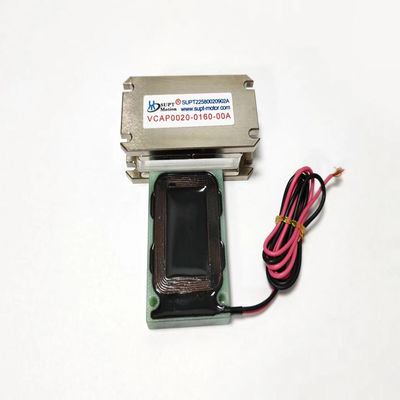
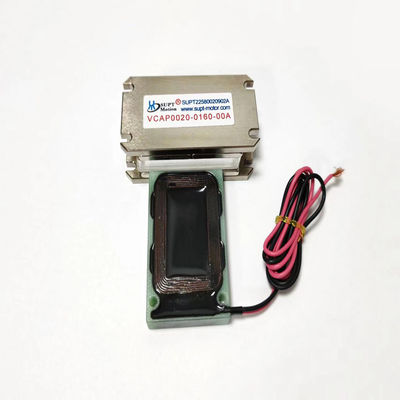
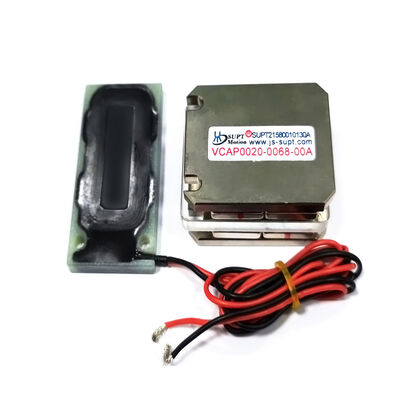
The VCAP0020-0068-00A is a parallel-jaw micro-gripper based on a design featuring two flat voice coils arranged in opposition. Each jaw is driven independently; consequently, the gripper’s closure is based on force rather than a fixed stroke, which is precisely what is required in the semiconductor and electronics assembly sectors when handling bare chips, thin wafers, optical components and small metal parts.
This flat voice coil motor module is supplied as a bespoke unit: the jaw geometry, finger mounting configuration, cable exit and vacuum port can all be tailored to the customer’s end-effector.
Solution
Robotic end-effectors in wafer fabs typically utilise pneumatic grippers similar to those found in machining workshops; this choice results in the gripping force being fixed at a single value for all workpieces handled by the robot. Excessive gripping force can cause thin wafers to crack, whilst insufficient force can cause them to fall; the robot controller is unable to detect either of these situations until the workpiece has fallen to the floor.
This problem can be resolved by using voice coils to drive each jaw: the gripping force becomes an adjustable parameter, meaning the same gripper can handle a 50-micrometre wafer and a 3-millimetre copper heat sink with two different gripping force values respectively. Furthermore, the voice coil current confirms that the workpiece is securely gripped, rather than relying solely on pneumatic closure.
As the grippers operate independently, the fixture can also centre the workpiece by applying force, thereby eliminating the need for precise placement within the tray; at the same time, it can detect feeding errors by detecting discrepancies in the positions of the two grippers. As no pneumatic lines are required, the end-effector requires only a single electrical connector, which simplifies the tool-changing process on the robotic arm and prevents flexible hoses from generating particulate matter in the cleanroom.

Specifications
| Parameter | Value |
|---|---|
| Model | VCAP0020-0068-00A |
| Actuator type | Flat planar voice coil actuator, moving coil |
| Peak force | 20 N (intermittent) |
| Continuous force at 25°C | 5.5 N |
| Total stroke | 6.8 mm |
| Maximum voltage | 8.2 V |
| Back EMF constant | 4.4 V/m/s |
| Length × width × height | 39 × 50 × 21.5 mm |
| Position feedback | External linear encoder, customer supplied |
| Cooling | Natural convection, heat sink optional |
| Duty cycle | 100% at continuous force with heat sink |
| Product Model | Peak Force (N) |
Continuous Force at 25℃(N) |
Total Stroke (mm) |
Max Voltage (V) |
Back EMF Constant (V/m/s) |
Length (mm) |
Width (mm) |
Height (mm) |
| VCAP0020-0068-00A | 20 | 5.5 | 6.8 | 8.2 | 4.4 | 39 | 50 | 21.5 |
| VCAP0020-0160-00A | 20 | 5.3 | 16 | 27.6 | 4.4 | 59 | 50 | 22.5 |
| VCAP0030-0200-00A | 30 | 12.3 | 20 | 24.3 | 10.5 | 80 | 74 | 25 |
| VCAP0100-0020-00A | 100 | 47 | 4 | 41.2 | 80.1 | 110 | 105 | 51 |
Application
Robot end effectors for die and wafer handling, tray and magazine transfer in back end assembly, optical component pick and place, micro gear and connector insertion, fragile substrate handling in inspection robots, and laboratory automation grippers that need a programmable and repeatable gripping force.
FAQ
Q: How is gripping force set for a new part?
A: It is a value in the robot program. The drive converts the command into coil current, and current into jaw force, so a new product recipe only needs a force number and a closing speed.
Q: Can the gripper tell whether a part is present?
A: Yes. When the jaws close on an object the current rises before the stroke is complete, and when they close on nothing the current follows the no load profile. The difference is a reliable presence signal without extra sensors.
Q: What if the two jaws meet an off centre part?
A: Because each jaw is driven independently, the jaws equalise force and self centre the part within the stroke. The position difference between the jaws is also a useful measure of how far off centre the part was presented.
Q: Is a customized jaw geometry possible?
A: Yes, that is the normal case. Send the part drawing and the required force, stroke and envelope, and we return a jaw design with a mounting pattern that matches your existing fingers.
Q: What is the lead time for a customized gripper?
A: Samples in about 3 weeks from drawing approval, series units in 5 to 6 weeks. Standard 20 N configurations with a generic finger pattern can ship from stock in about 10 days.
Ordering Information
Quote requires the part drawing, gripping force range, jaw stroke, mounting pattern and available envelope. A 3D model and force calibration report are supplied with each unit.
Recommended Products